End Effector (Wafer Robot Hand)
An end effector is the part at the tip of a robot arm that actually holds the object. In semiconductor equipment it means the hand, or blade, of the transfer robot that carries wafers. A wafer is moved by robots many times during a single process step, from the FOUP into the tool and from the load lock into the chamber, and each move involves the end effector.
Also called: robot hand, robot blade, wafer finger
Diagram
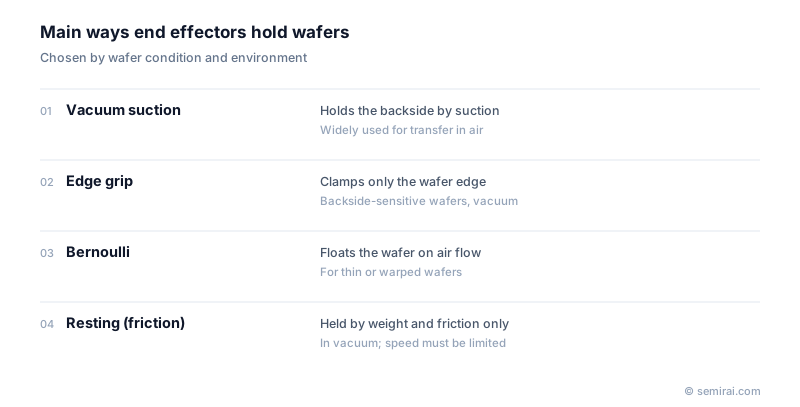
Ways of holding a wafer
Vacuum suction draws air through small holes in the hand to hold the wafer by its backside and is widely used for transfer in air. Edge grip clamps only the wafer edge and is used when the backside must not be touched. The Bernoulli method floats the wafer on an air flow without contact, which suits thin or warped wafers.
Inside vacuum tools, suction cannot work, so wafers are held by edge grip, electrostatic force or simply by their weight and friction on the hand. In that case the robot's speed and acceleration must be limited so the wafer does not slide.
Design requirements
End effectors must be thin, light and stiff. In a FOUP the wafers are only about 10 mm apart, and the hand has to slide between them and lift one wafer out. Materials include ceramics such as alumina and carbon-fibre composites, with heat-resistant materials chosen for hot wafers.
Hands often carry sensors that confirm whether a wafer is present and correctly positioned. Preventing drops, cracks from collisions, backside scratches and particles is the main goal.
Japanese companies involved
- Yaskawa Electric and RORZE make wafer transfer robots used in atmospheric and vacuum handling systems.
- Hirata Corporation makes EFEMs and wafer transfer units in which these robots and their end effectors operate.
- RORZE · Wafer handling robots and sorters
- Yaskawa Electric · Wafer transfer robots
- Kyocera · Package substrates and ceramic components
- Hirata Corporation · EFEMs, load ports and wafer transfer units
FAQ
How are wafers held inside vacuum equipment?
Vacuum suction is impossible in a vacuum, so tools use edge-grip claws, electrostatic holding, or simply carry the wafer resting on the hand by gravity and friction. Motion profiles are tuned so acceleration never exceeds what friction can hold.
How are thin or warped wafers handled?
Large warpage defeats vacuum suction and thin wafers break easily, so non-contact Bernoulli hands or hands with a wider suction area are used. Advanced packaging often involves heavily warped reconstituted wafers moulded in resin, and dedicated hands have been developed for them.
Related pages
Sources
Last updated: November 13, 2026